AnyDexRetarget × CRAFT
Mapping human hand landmarks to a CRAFT Hand
Overview
Human and robot hands have different joint arrangements. The retargeting pipeline uses tracked landmarks to choose a corresponding pose for the robot.
Comparing poses
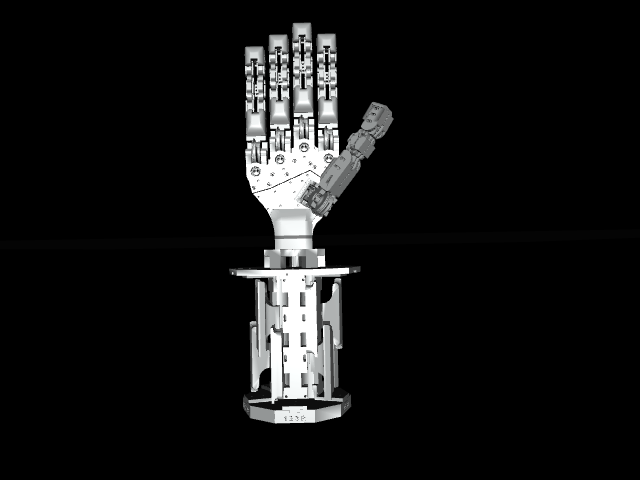
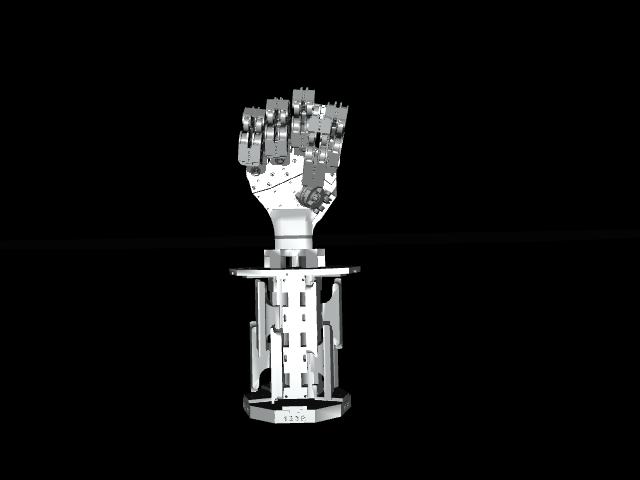
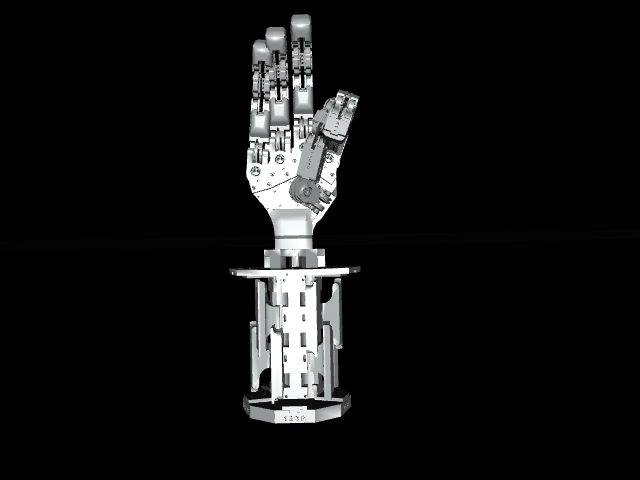
The simulation represents 20 finger joints, with 15 independent hardware variables. Compare the open pose, fist, and thumb–index pinch to see how the fingertips change position across these targets.