CR3 × CRAFT Teaching
Keyboard and camera inputs for a simulated arm and hand
Overview
This project combines Cartesian arm control with finger targets from MediaPipe. Operators can use a keypad for arm motion or calibrate a torso-relative frame for camera-based teaching.
Control in MuJoCo
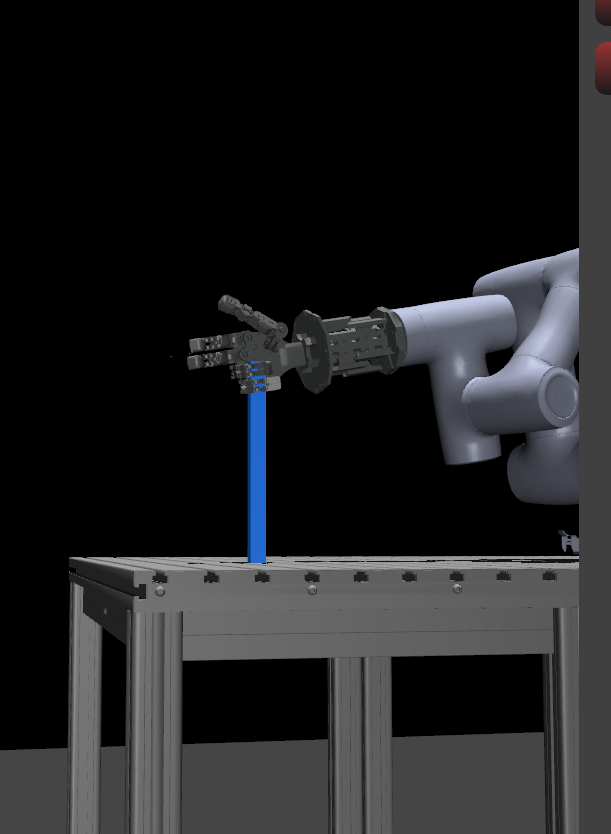
The first clip illustrates a programmed Cartesian reach in the project scene. The repository also includes the interactive keyboard and torso-teaching programs, with arm and hand position actuators and instructions for camera calibration.
Teaching scene