DexJoCo Teleoperation
Cartesian arm commands and finger motion on CR3 × CRAFT
Overview
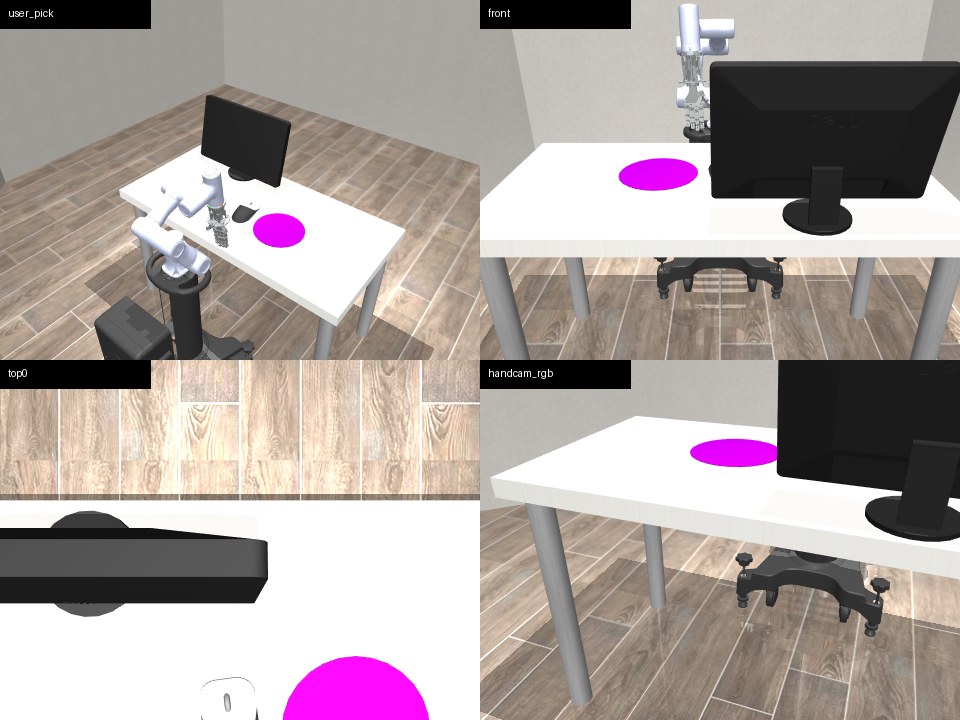
The MuJoCo environment combines a six-axis CR3 arm with a CRAFT Hand. Camera and keyboard inputs map into the same command interface so they can be tested in the same scene.
Action interface
Each action contains a target position, orientation, and 15 finger commands. The video uses a scripted motion along the X axis with finger flexion. The additional camera views show how the same workspace appears from different angles.
Camera views