Dummy V2
From a CAD model to browser control and simulated grasping
Overview
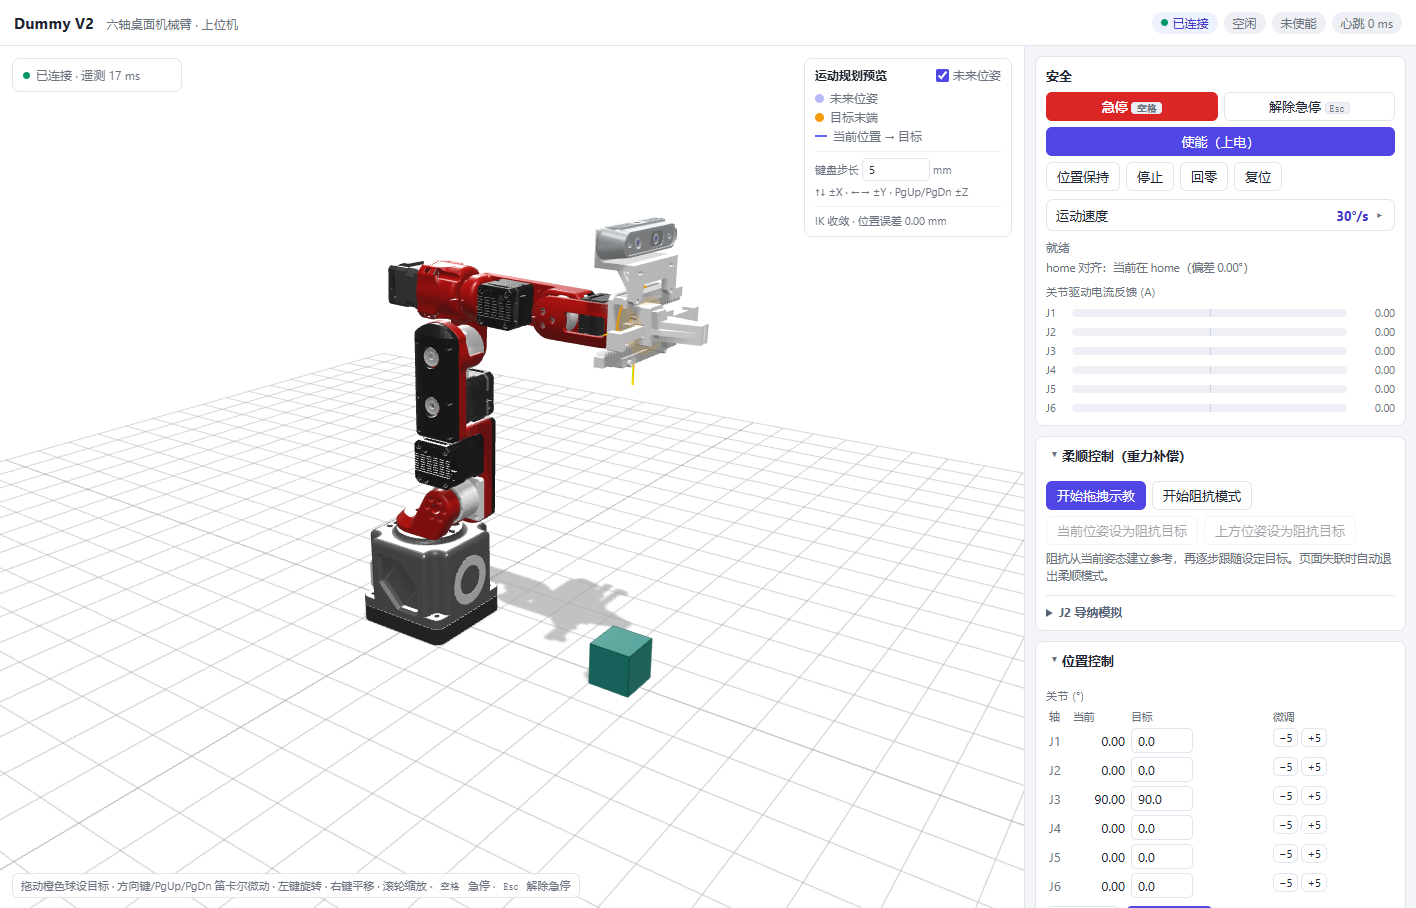
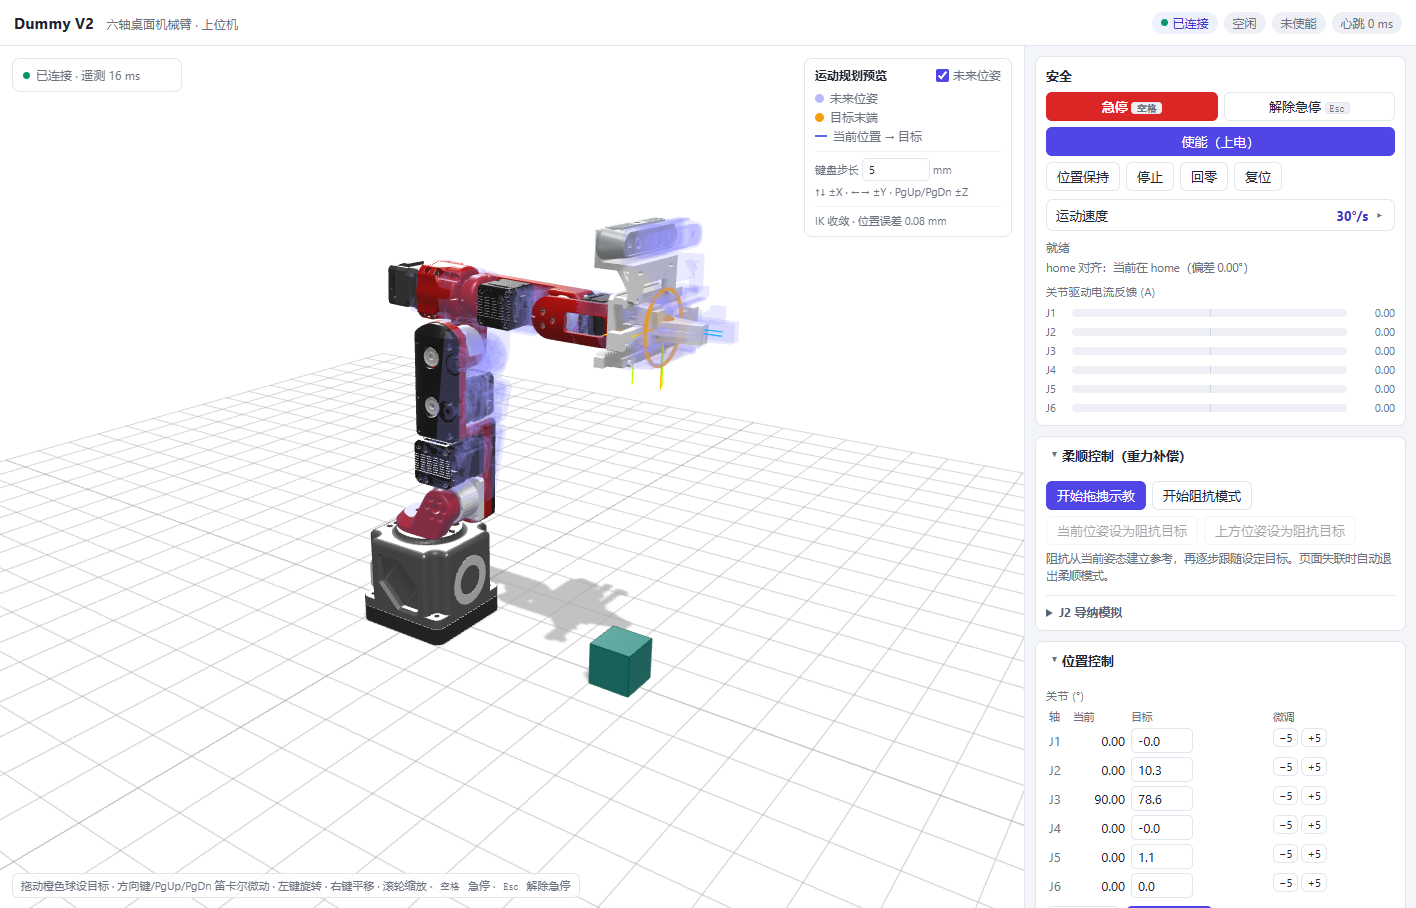
The desktop arm, gripper, and depth camera share a robot description. The same geometry can be inspected in the browser and used to study a grasp from an external camera and a wrist-mounted camera.
Model and controls
J1–J5 position the arm, J6 drives the gripper, and the camera mount follows J5. The browser screenshots show a mock session with joint control and a translucent inverse-kinematics target. Hardware validation is ongoing.
Browser interface